A generally applicable spectral design of non-collocated vibration suppression performed primarily by a delayed resonator is presented. The vibration suppression is achieved by direct assignment of imaginary axis zeros of the transfer function between the periodic disturbance force and the target’s displacement. In order to increase the stability margin and to widen the range of frequencies which can be suppressed, the non-collocated vibration absorption by a delayed resonator is supplemented by a stabilizing controller tuned by spectral optimization. A unifying aspect of the resonator and the controller is that both use time-delayed output feedback where both the gains and delays are used as controller parameters. Another important aspect of the proposed method is that it can be applied to a system of general structure, where possibly paths exist between the entry point of the disturbance force and the non-collocated absorber that by-pass the suppression target, thereby precluding the existence of a resonating substructure. The proposed method has been validated using both simulations and on an experimental setup.
You may also like
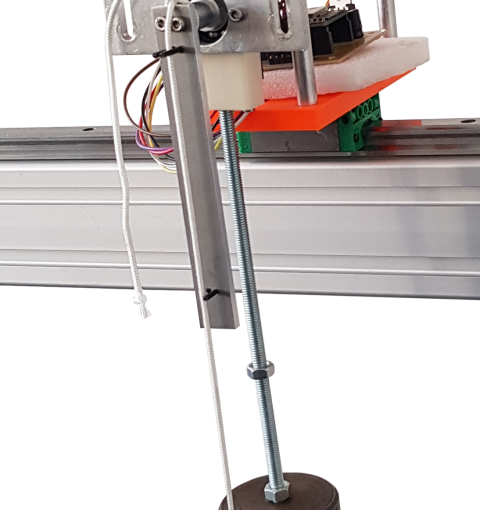
This setup was used for experiments with vibration reduction by absorption in multiple dimensions. An experimental setup containing an absorber demonstrator with […]

The paper presents a controller design method that adopts the well-known Youla-Kučera parameterization for linear time-invariant time-delay systems. In particular, through the […]

Authors: Tarunraj Singh, Tomáš Vyhlídal, Jaroslav Bušek The focus of this paper is on the design of distributed delay multi-mode input shapers […]
A fully analytical controller design is proposed to tackle a periodic control problem for stable linear systems with an input delay. Applying […]